Wuhan University team builds bistable origami robot driven by nonuniform magnetic fields
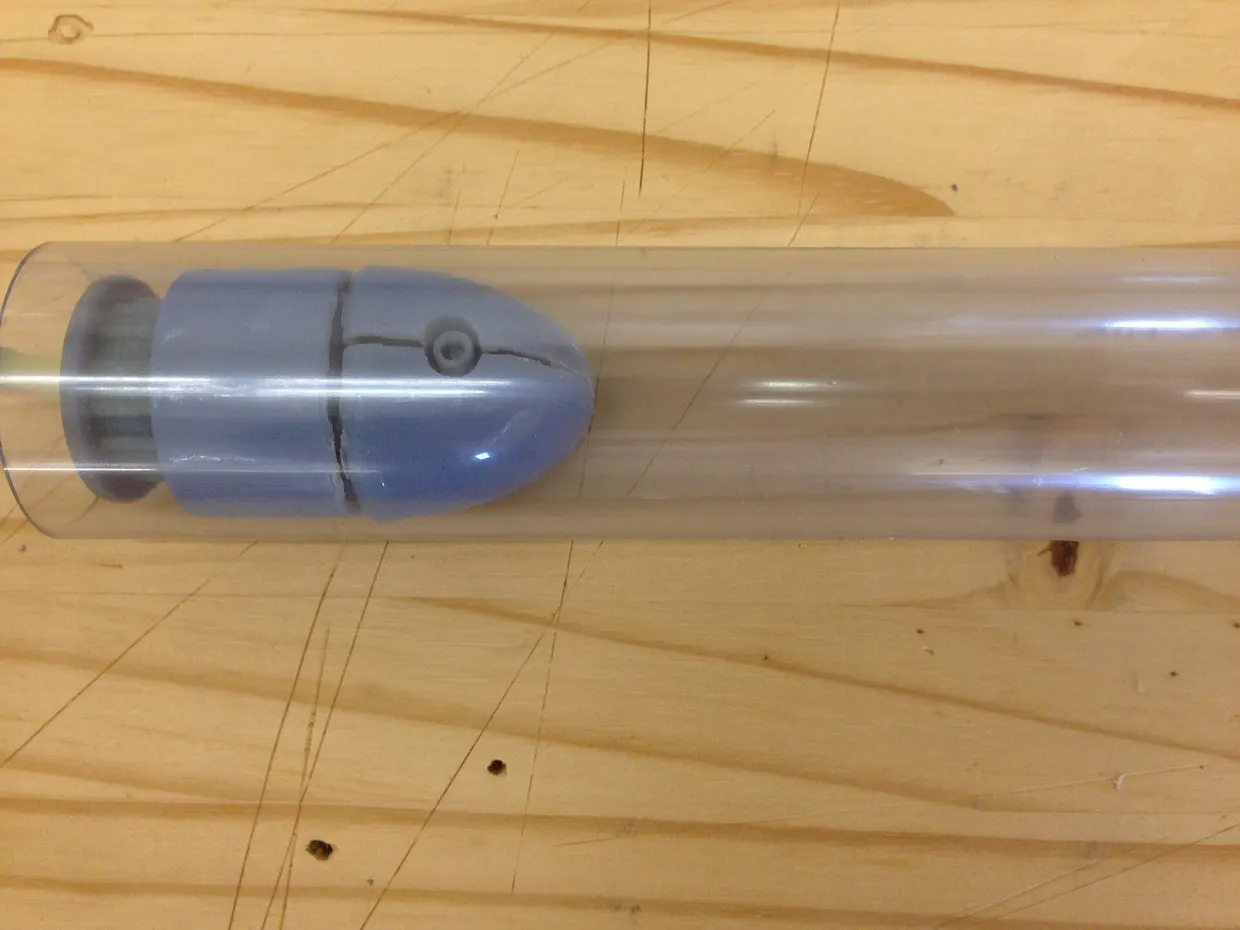
A laboratory prototype of a bistable origami mini-robot moves in low-uniform magnetic fields, shifting precision requirements from the field to the robot's geometry.
A research group from Wuhan University in China has described a bistable origami robot that moves under nonuniform magnetic fields. The work was published on 6 November 2026 in Nature Communications. The corresponding author is Yang Li, who is also affiliated with the State Key Laboratory of Transducer Technology of the Shanghai Institute of Microsystem and Information Technology, Chinese Academy of Sciences. nature.com
Nature Communicationsnature.comOpen source ↗ It is a laboratory demonstration, validated by analytical modeling, numerical simulation and experimental testing.
Geometry instead of field precision
Conventional magnetically controlled mini-robots require operation within highly uniform, high-precision magnetic fields, which are impractical for large spaces. In the new design, these requirements are offloaded onto the pre-programmed geometry of the robot's mechanical architecture.
The structures are bistable. At each stable state they show distinct deformation modes when subjected to small-amplitude magnetic perturbations. Transitions between the stable states are triggered by large-amplitude impulsive magnetic inputs and enable impulsive motions such as grasping.
Actuation system and demonstrated motions
To drive the structure, the authors developed a large-workspace magnetic actuation system that generates low-uniform magnetic fields. nature.com
Nature Communicationsnature.comOpen source ↗ According to them, the system can control the bistable origami structure to achieve the desired multimodal locomotion and manipulation.
The demonstrated capabilities include self-grasping and object capture. Adaptive locomotion modes — crawling, turning, tumbling, scampering, jumping and rolling — were shown at two different stable configurations.
The authors state that the results offer an approach for designing multi-functional, wireless mini- and microrobots intended for large spaces. The same set of three methods — analytical modeling, numerical simulation and experimental testing — underlies this conclusion.